AI Summary21 Oct 202611 Jumada I 1448 AH
AI Summary
21 Oct 202611 Jumada I 1448 AH
HIL-UMI Method Enhances Vision-Language Models for Robotics
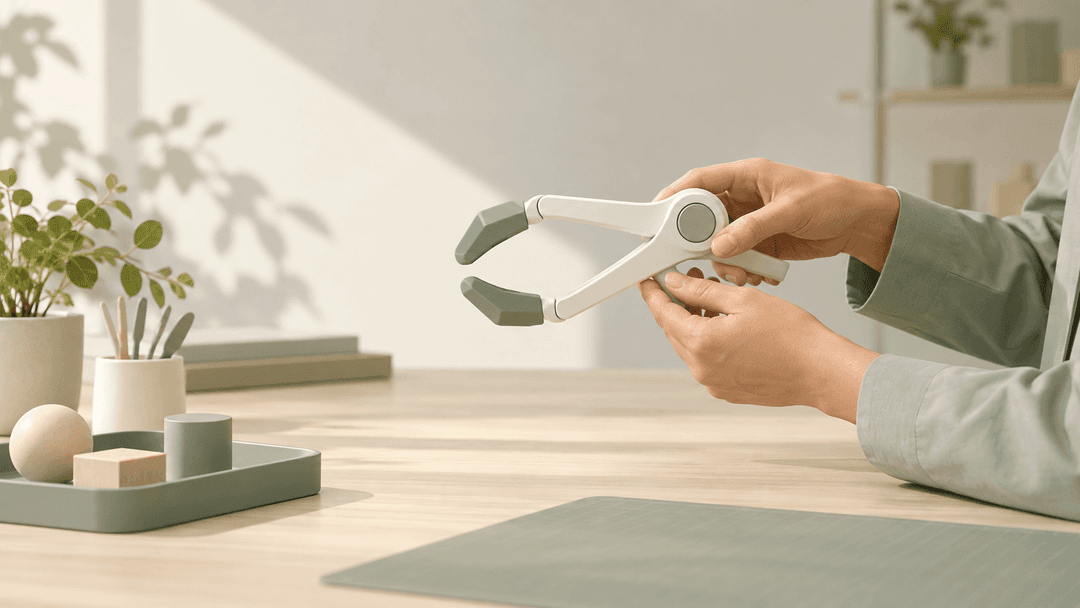
A team led by Hao Dong at Peking University, in collaboration with PrimeBot, has introduced HIL-UMI, a method for collecting correction data using a handheld gripper instead of a robotic arm. This approach allows for faster and more efficient data collection, as cameras record the scene while the operator performs the task.
HIL-UMI enhances the learning process by reducing the time spent on robot resets, utilizing a Universal Manipulation Interface for data gathering. The system demonstrates higher efficiency in data collection, achieving superior results compared to the traditional HG-DAgger method, reflecting a significant performance improvement.
Follow these topics
Sign in to follow the topics that matter to you
This summary is generated with AI and receives periodic editorial review. Refer to the original source for full details.
0
0 reading now
Insight Score
Rate to unlock
You have not rated yet.
Sign in to react, rate, and save. Sign In